Case study · Stargate Data Centre, UAE
Four workers pushed debris all day.
The robot runs that route on its own now.
Measured over 28 recorded trips at the Stargate data centre site: what manual material movement was costing the crew in strain and wasted capability, and what changed when an autonomous machine took the route off them.
- Stargate Data Centre
- ALEC, UAE
- 28 trips recorded
- Worker impact study
- of the route's physical work now carried by the machine
- 93%
- workers taken off the debris route entirely
- 4
- no longer pushed under load, per worker per shift
- 2.1 km
- per trip, now carried by the machine instead of four people
- 400 kg
- returned to trade work every month
- 858 hrs
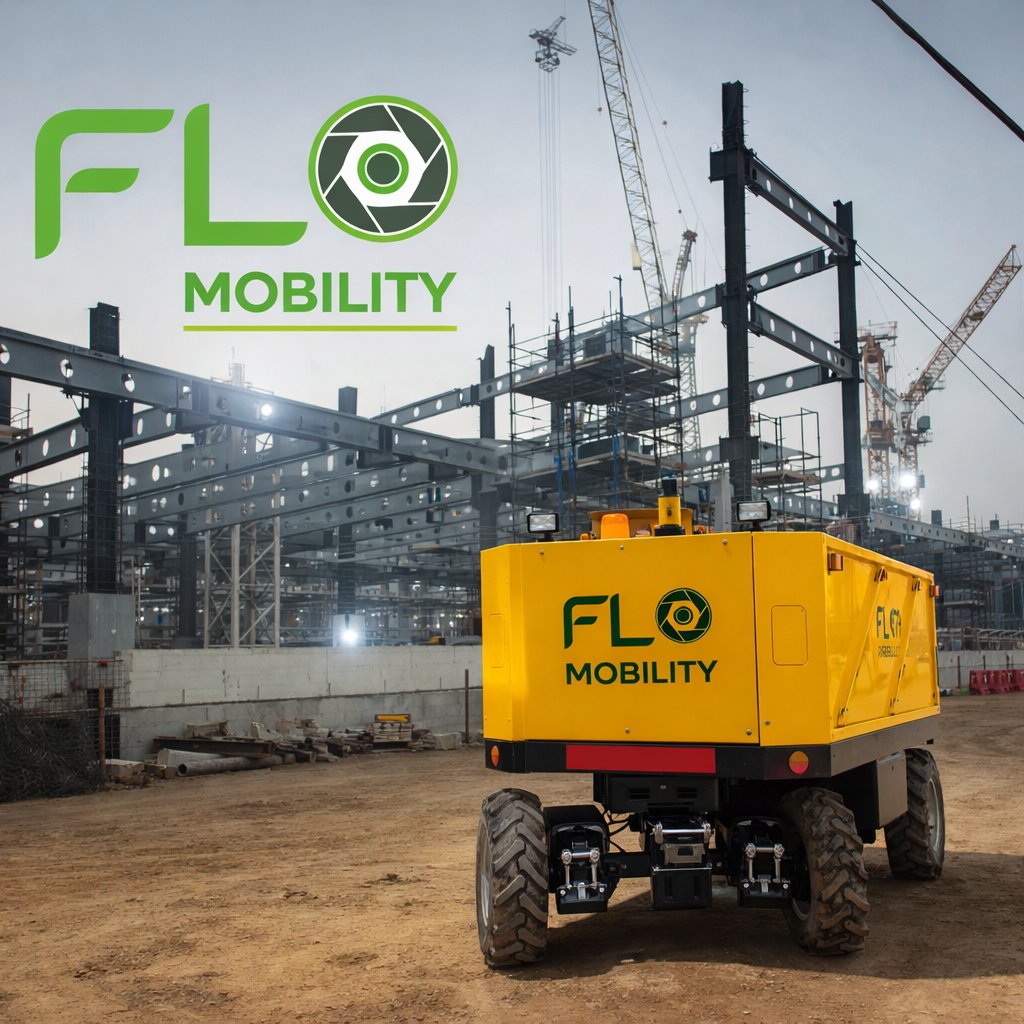
Site footage
The same route, worked two ways
Two workers to one loaded trolley
Full body effort for the length of the route
A crew gathered round one load
Four hands minimum, every single trip
The robot runs the route alone
Nobody walking it, nobody pushing it
1What the job asked of the body
A full shift of strain that produced nothing
Debris movement from the building to the garbage yard ran on four workers and a pallet trolley. Four hundred kilos behind four people, over a route with sloped sections and stretches of broken ground. They averaged 76 minutes per trip and completed about seven trips in a ten hour shift, which is very nearly the whole working day. Not one minute of it advanced the build.
Load behind the crew, every trip
400 kg
Seven times a shift
The same 400 kg, trip after trip, all day
Distance walked under load
2.1 km
4.2 km walked in total
Loaded trolley outbound, empty trolley back
Push force each worker sustains
100–200 N
Over the limit on slopes
Indicative limit for sustained pushing is 100–150 N
Shift hours consumed by the route
8.9 hrs
Of a 10 hour shift
Four workers with no capacity left for anything else
Physical burden per worker, per ten hour shift
What the body absorbed on the manual method, and what remains once the robot runs the route
- Distance pushed under load
- Manual2.1 km of loaded trolleyRobotNoneFully removed
- Unloading by hand
- Manual7 unload cycles of 400 kgRobotNoneAuto dump
- Hours tied to the route (of a 10 hour shift)
- Manual8.9 hrs per workerRobot2.5 hrs, one personPart time
Human hours the route consumes per shift
35.5 man hours down to 2.5, a 93% reduction in human effort
| Category | Manual crew | Robot |
|---|---|---|
| Manual crew of four | 35.5 hrs | No Robot value |
| Robot, part time cover | No Manual crew value | 2.5 hrs |
Where the 76 minutes of a manual trip went
71% of every trip was hands on the material, loading and unloading by hand
| Category | Hands on the material | Walking the route |
|---|---|---|
| Loading by hand | 26 min | No Walking the route value |
| Pushing out | No Hands on the material value | 11 min |
| Unloading by hand | 28 min | No Walking the route value |
| Return | No Hands on the material value | 11 min |
Most of the trip was hands on the material
Loading and unloading by hand accounted for 54 of every 76 minutes. The walking was the visible part of the job, but the lifting and lowering is where the bodies were spent, and auto dump removes half of that outright.
Nothing about the task was skilled
Four workers, a trolley and a 300 metre route. The work demanded stamina and nothing else, from people hired to build a data centre. That is the real waste in the old method, and it never shows up on a programme report.
2Fatigue, measured rather than assumed
The gap between people and machine is the fatigue curve
Head to head trials on a 300 metre loop at the site, run at a light trial load and again at the 400 kg the route actually demands, plus a continuous 60 minute endurance run. Light, the two are level. At 400 kg the difference is the human body reaching its limit.
Light trial load, 300 m loop (robot vs crew)
3:27 vs 3:20
Level, 7 seconds apart
A fit worker matches the robot when the load is light
At the route load of 400 kg (robot vs crew)
3:32 vs 5:37
Crew 2:05 slower per trip
The robot holds its pace. The crew cannot.
Robot pace decay over 60 minutes
None
Trip 19 matches trip 1
No rotation, no recovery breaks, no drop off
Workers needed to hold that pace
Two, alternating
Even at a light load
One person could not sustain the cycle for an hour
Time for one 300 m loop, by load
Level at the light trial load, then human pace falls away at 400 kg
| Category | Human crew | Robot |
|---|---|---|
| Light trial load | 3:20 | 3:27 |
| Route load, 400 kg | 5:37 | 3:32 |
Sixty minutes of continuous cycling
19
Trips in 60 minutes, robot running unattended
No rotation and no rest cycle. The pace at the end of the hour is the pace at the start, and it would still be the pace at the end of a ten hour shift.
20
Trips in 60 minutes, two workers alternating
Two people were needed to match one robot at 90 kg, a fraction of the 400 kg the route demands, one working while the other recovered. A single worker could not hold the cycle.
3The exposures that came with doing it by hand
Three risks that only existed because people carried the load
Recorded across the debris route and the store clearance runs at the site. Each one is a consequence of the task being done with human bodies, and each one disappears when the task stops being done that way.
400 kg pushed over slopes and broken ground
The route was not flat concrete. On the sloped and rough sections the force each worker had to sustain rose above the recommended limit for pushing, seven times a shift. No technique or training closes that gap, because the gradient does not negotiate.
Overexertion risk removed at source
Hand unloading on every single trip
Twenty eight minutes of each trip was spent lowering debris out of the trolley by hand, and each load was wrapped before transport to stop spillage. The robot's auto dump does the unload, so both the lowering and the wrapping stop happening.
Repetitive stoop cycles eliminated
Scrap standing for days at a time
Clearing the stores meant pulling a four person crew off productive work, so it kept getting deferred and scrap sat for two to three days, turning working areas into trip and fire hazards. The robot clears on a 44 minute cycle, so the pile never forms.
Housekeeping risk designed out
People tied to the route
4, all shift
Four workers on the pallet trolley for 8.9 of 10 hours
None
One part time operator on call
The machine runs the route autonomously
Load behind the crew
400 kg
Four workers to a trolley, over slopes and broken ground
Nothing
The 400 kg sits on the machine
Carries the full load up the slopes unassisted
Distance under load
300 m per trip
Pushed out loaded, then 300 m back empty, seven times a shift
Zero
Nobody walks the route
No pushing, no pulling, no carrying
Unloading
By hand, every trip
28 minutes of lowering debris out of the trolley
Auto dump
Step deleted, not shortened
No lowering by hand and no wrapping beforehand
Clearance interval
Every 2 to 3 days
Deferred whenever the crew was needed elsewhere
Continuous, 44 min
The pile never accumulates
Runs without taking anyone off their own work
Summer rules compress the work, the robot absorbs it
Under the UAE Occupational Heat Stress Prevention Policy, outdoor work in open areas stops between 12.30pm and 3pm from 15 June to 15 September, and daily hours are capped at eight in those months. A manual crew loses that window and has to make it up. A machine cycling at a fixed pace does not.
Removing the task beats managing the risk
Wrapped pallets, handling training and team lifts are all controls layered on top of a task that is inherently over the limit. Taking the task off people removes the need for the controls, which is the top of the hierarchy rather than the bottom.
4Where the four workers went
The point was never fewer people. It was better work.
Four workers came off the debris route and none of them left the site. One picked up the robot as a part time responsibility alongside other duties, stepping in when the machine needs a hand. The other three went to the work they were actually hired for.
| Role before | Role after | What changed for them |
|---|---|---|
| Trolley crew, 1 of 4 | Robot operator, part timeGrade up | Covers the machine alongside other duties, stepping in when it needs an intervention. Roughly a quarter of a shift, and a skilled responsibility rather than a stamina one. |
| Trolley crew, 2 of 4 | Internal fitout support | Moved to the work face on drylining and partition installation. Work that puts progress on the programme and builds a trade skill. |
| Trolley crew, 3 of 4 | MEP first fix assistance | Supporting cable and conduit installation with the services teams rather than clearing what those teams leave behind. |
| Trolley crew, 4 of 4 | Finishes and flooring support | On the floors with the finishing teams, on work that is measured by what gets installed rather than by what gets carried away. |
Human effort redirected out of haulage
- Workers tied to the debris route
- 4 down to none
- Man hours the route consumed per shift
- 35.5 hours
- Part time operator cover per shift
- 2.5 hours
- Man hours returned to productive trades
- 858 hours per month
- Share of the route's physical work now carried by the machine
- 93%
The same robot, pointed at work that helps rather than work that hurts
Once the debris route is automated, the machine is available for the material runs that currently eat skilled trade hours across the site.
Cable drums and conduit
Heavy drums and conduit bundles taken from the MEP store to the installation zone, instead of two electricians carrying them and arriving tired.
Ductwork and HVAC panels
Prefabricated duct sections and insulation panels moved to the floor, keeping fitout crews on installation rather than fetching.
Drylining and partitions
Stud frames and plasterboard in bulk to the work face. One robot run replaces several two person carries down a long corridor.
Fixtures and switchgear
Boxed lighting, distribution boards and switchgear staged at floor level ahead of the installation team arriving.
Flooring and tiling
Tile boxes, screed bags and adhesive buckets, which are the heaviest and most repetitive carries on any fitout floor.
Plumbing and pipework
Pipe bundles, valves and sanitary ware to shaft areas and bathroom zones, taken off the shoulders of the plumbing crew.
The strain is gone, not shifted
No pushing under load, no carrying distance, no hand unloading. The machine took the parts of the job that wore people down, and it does not hand them to somebody else.
Autonomous, not just assisted
The robot runs the route by itself. One worker covers it part time and steps in when needed, which is a supervision role rather than a haulage one.
The capability comes back
858 man hours a month move from hauling debris to building the data centre, and the crew that used to push a trolley is now on the work the programme is measured by.
See what your site could save
Material Movement Robot, Robotics as a Service. Model your own route with the ROI calculator, or talk to us about a site trial.
Method
Based on 28 trips recorded on site: 12 robot and 4 manual debris trips, 4 store clearance cycles, and 8 head to head load trials. Basis for derived figures: 300 m one way route including sloped sections and stretches of broken ground, 400 kg per loaded trolley trip, 4 trolley workers per trip, part time operator cover at a quarter of a shift, 10 hour shift, 26 working days. Handling limits from the NIOSH lifting equation, ISO 11228-1 and ISO 11228-2. Construction injury shares from the US CDC overexertion analysis of construction musculoskeletal disorders.